 Ranked
Boston Dynamics gives Atlas a four-finger, 13-degree-of-freedom hand
The company says the new hand drops the little finger and is designed for tool use, simulation training and volume manufacture.
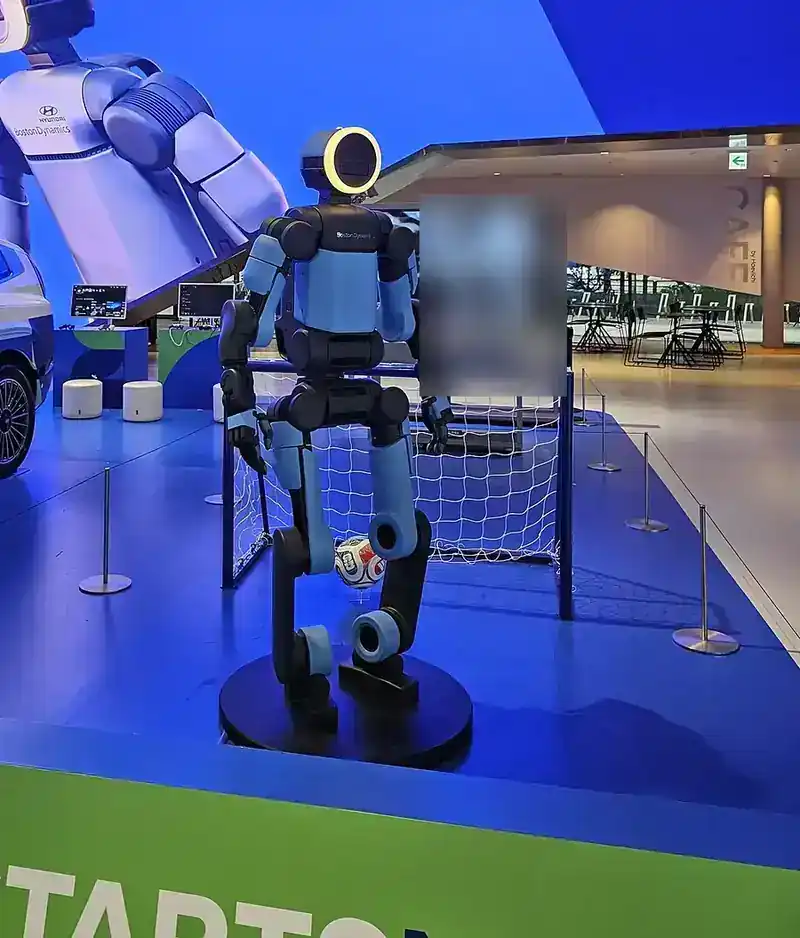
Boston Dynamics has described a new hand for its Atlas humanoid in a blog post dated 1 October. The company says it has four fingers and 13 degrees of freedom, up from seven on the previous design.
It says every joint uses one type of direct-drive actuator, and that pressure sensors cover the fingertips and palm. The company says the aim is tool work, citing triggered tools and in-hand reorientation.
The team says it left out the little finger because the extra actuators added cost, volume and failure risk. The company also says the hand is built for high-fidelity simulation, so control policies can be trained in simulation, and for mass manufacturing.
No price, availability date or load rating for the hand is given in the sources we checked.
Sources
Specs: Boston Dynamics Atlas full specifications
Written by the RankedRobot news desk (AI-assisted, human-reviewed) from the sources above; checked 2026-10-03. Claims are attributed to whoever makes them. Spotted an error? corrections@rankedrobot.com